Project Page

Projects

Selected robotics, interaction, and software projects.

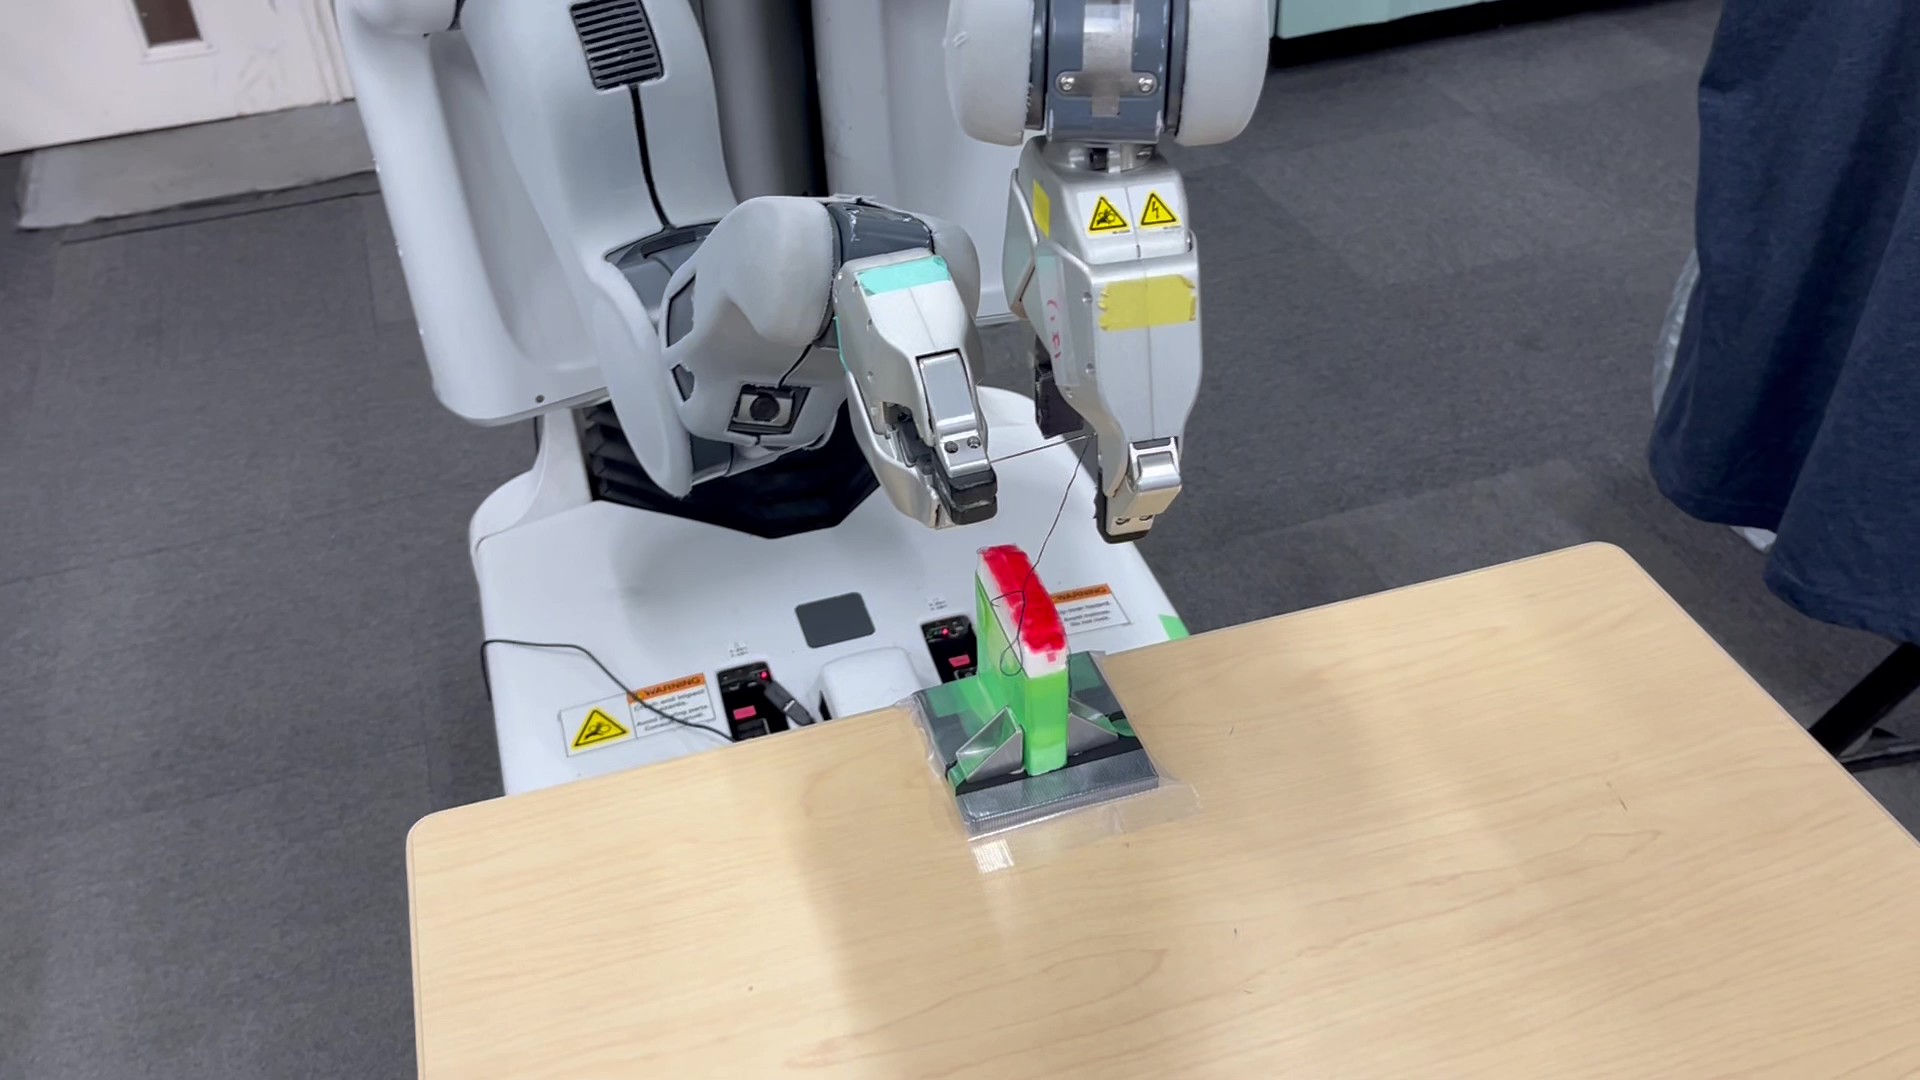
PR2 robot performing a continuous suture

Continuous Suture by PR2

We focused on the importance of suture length management and force feedback, and achieved continuous autonomous suturing using the PR2 dual-arm personal robot. This work was presented at the Annual Congress of the Japan Society of Computer Aided Surgery.

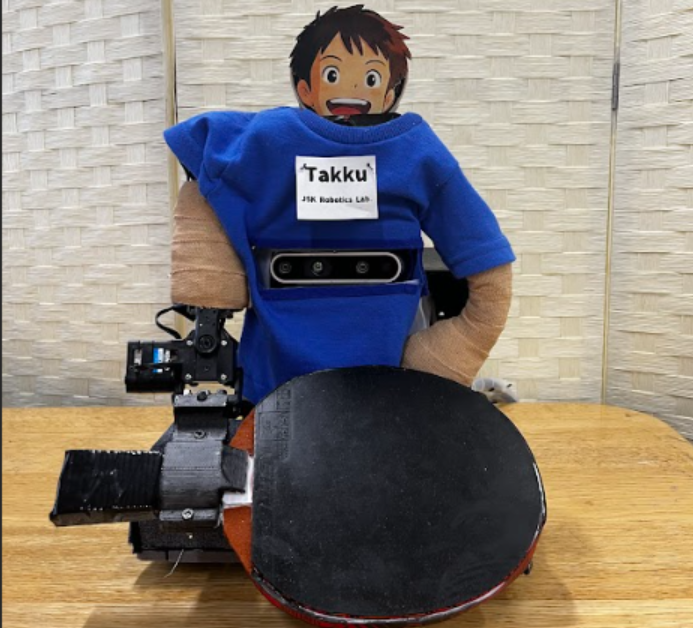
Takku, a desktop table tennis robot

Takku

We developed a table tennis robot that recognizes a ball with a camera and returns it on a tabletop, and designed and built a custom robot system and arm with human-like motion and appearance.

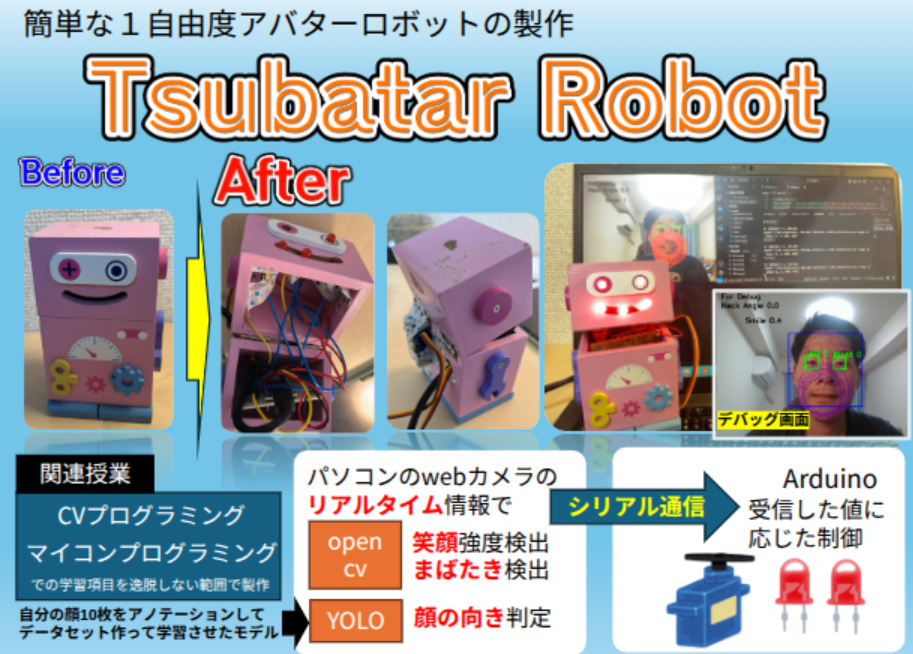
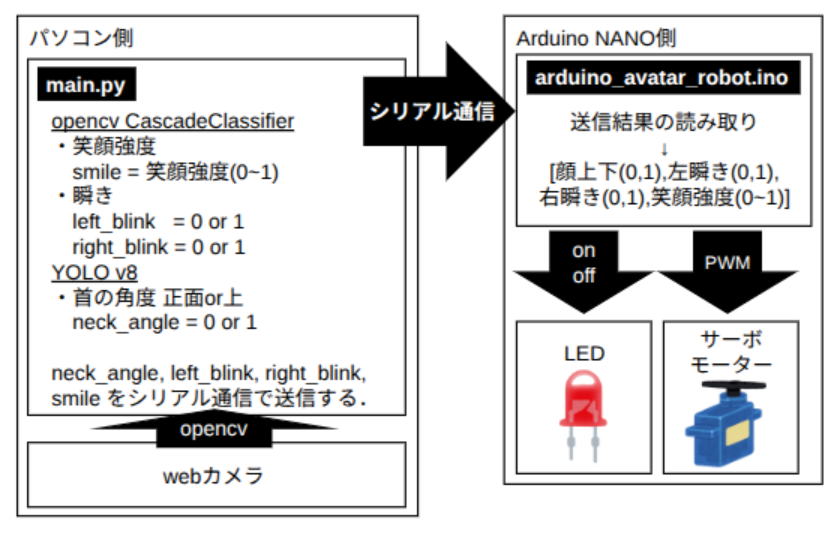
Tsubatar avatar robot Tsubatar system diagram

Tsubatar Robot

We developed a one-DoF avatar robot that recognizes human faces, smiles, blinks and head posture using YOLO and OpenCV, and performs real-time interaction and expression. This project was presented at the Advanced Programming in Mechanical Engineering Conference.

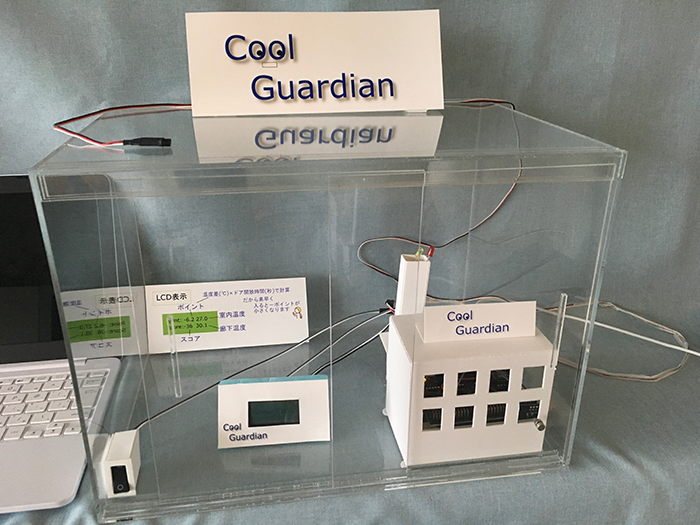
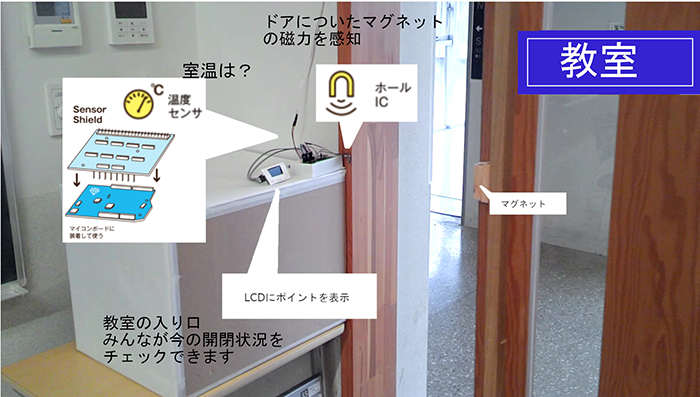
Cool Guardian device Cool Guardian concept diagram

Cool Guardian

At the Rohm Open Hack Challenge 2018 I developed a system that reduces energy waste from air conditioners using gamification, electronics prototyping and microcontroller programming. Despite being a high school student at the time, I received the Excellence Award.

Julia programming language logo

Julia Packages

I maintain two Julia packages for robotics and control applications.

ROS2.jl is a Python wrapper package for the ROS 2 Python client, rclpy. It helps integrate Julia's robot modules with ROS. For ROS 1, RobotOS.jl is available, and an example connecting Julia's inverse kinematics model with RobotOS can be found on GitHub.

DualQuatUtils.jl is a utility module for rotations, quaternions and dual quaternions in Julia, intended for robotics, drone control and motion planning. Julia's default Quaternion does not support dual quaternions, which makes this package useful.

I also worked as a software engineer using Julia at Proxima Technology Inc.